Scott (Seongwon) Lee

Scott (Seongwon) Lee

Scott (Seongwon) Lee

Ph.D. Candidate · Robotics
University of Illinois Urbana-Champaign

Open to full-time opportunities · Get in touch

I study task and motion planning, multi-robot systems, and agentic systems with Nancy M. Amato at UIUC .

Previously, as a Ph.D. Resident at X, the Moonshot Factory , I worked on wet-lab automation with robotics and multi-agent LLMs. I earned my bachelor’s in Mechanical Engineering at Yonsei University  (2021), advised by Jongeun Choi.

Research

Lazy-DaSH Image
Lazy-DaSH: Lazy Approach of Hypergraph-based Multi-robot Task and Motion Planning
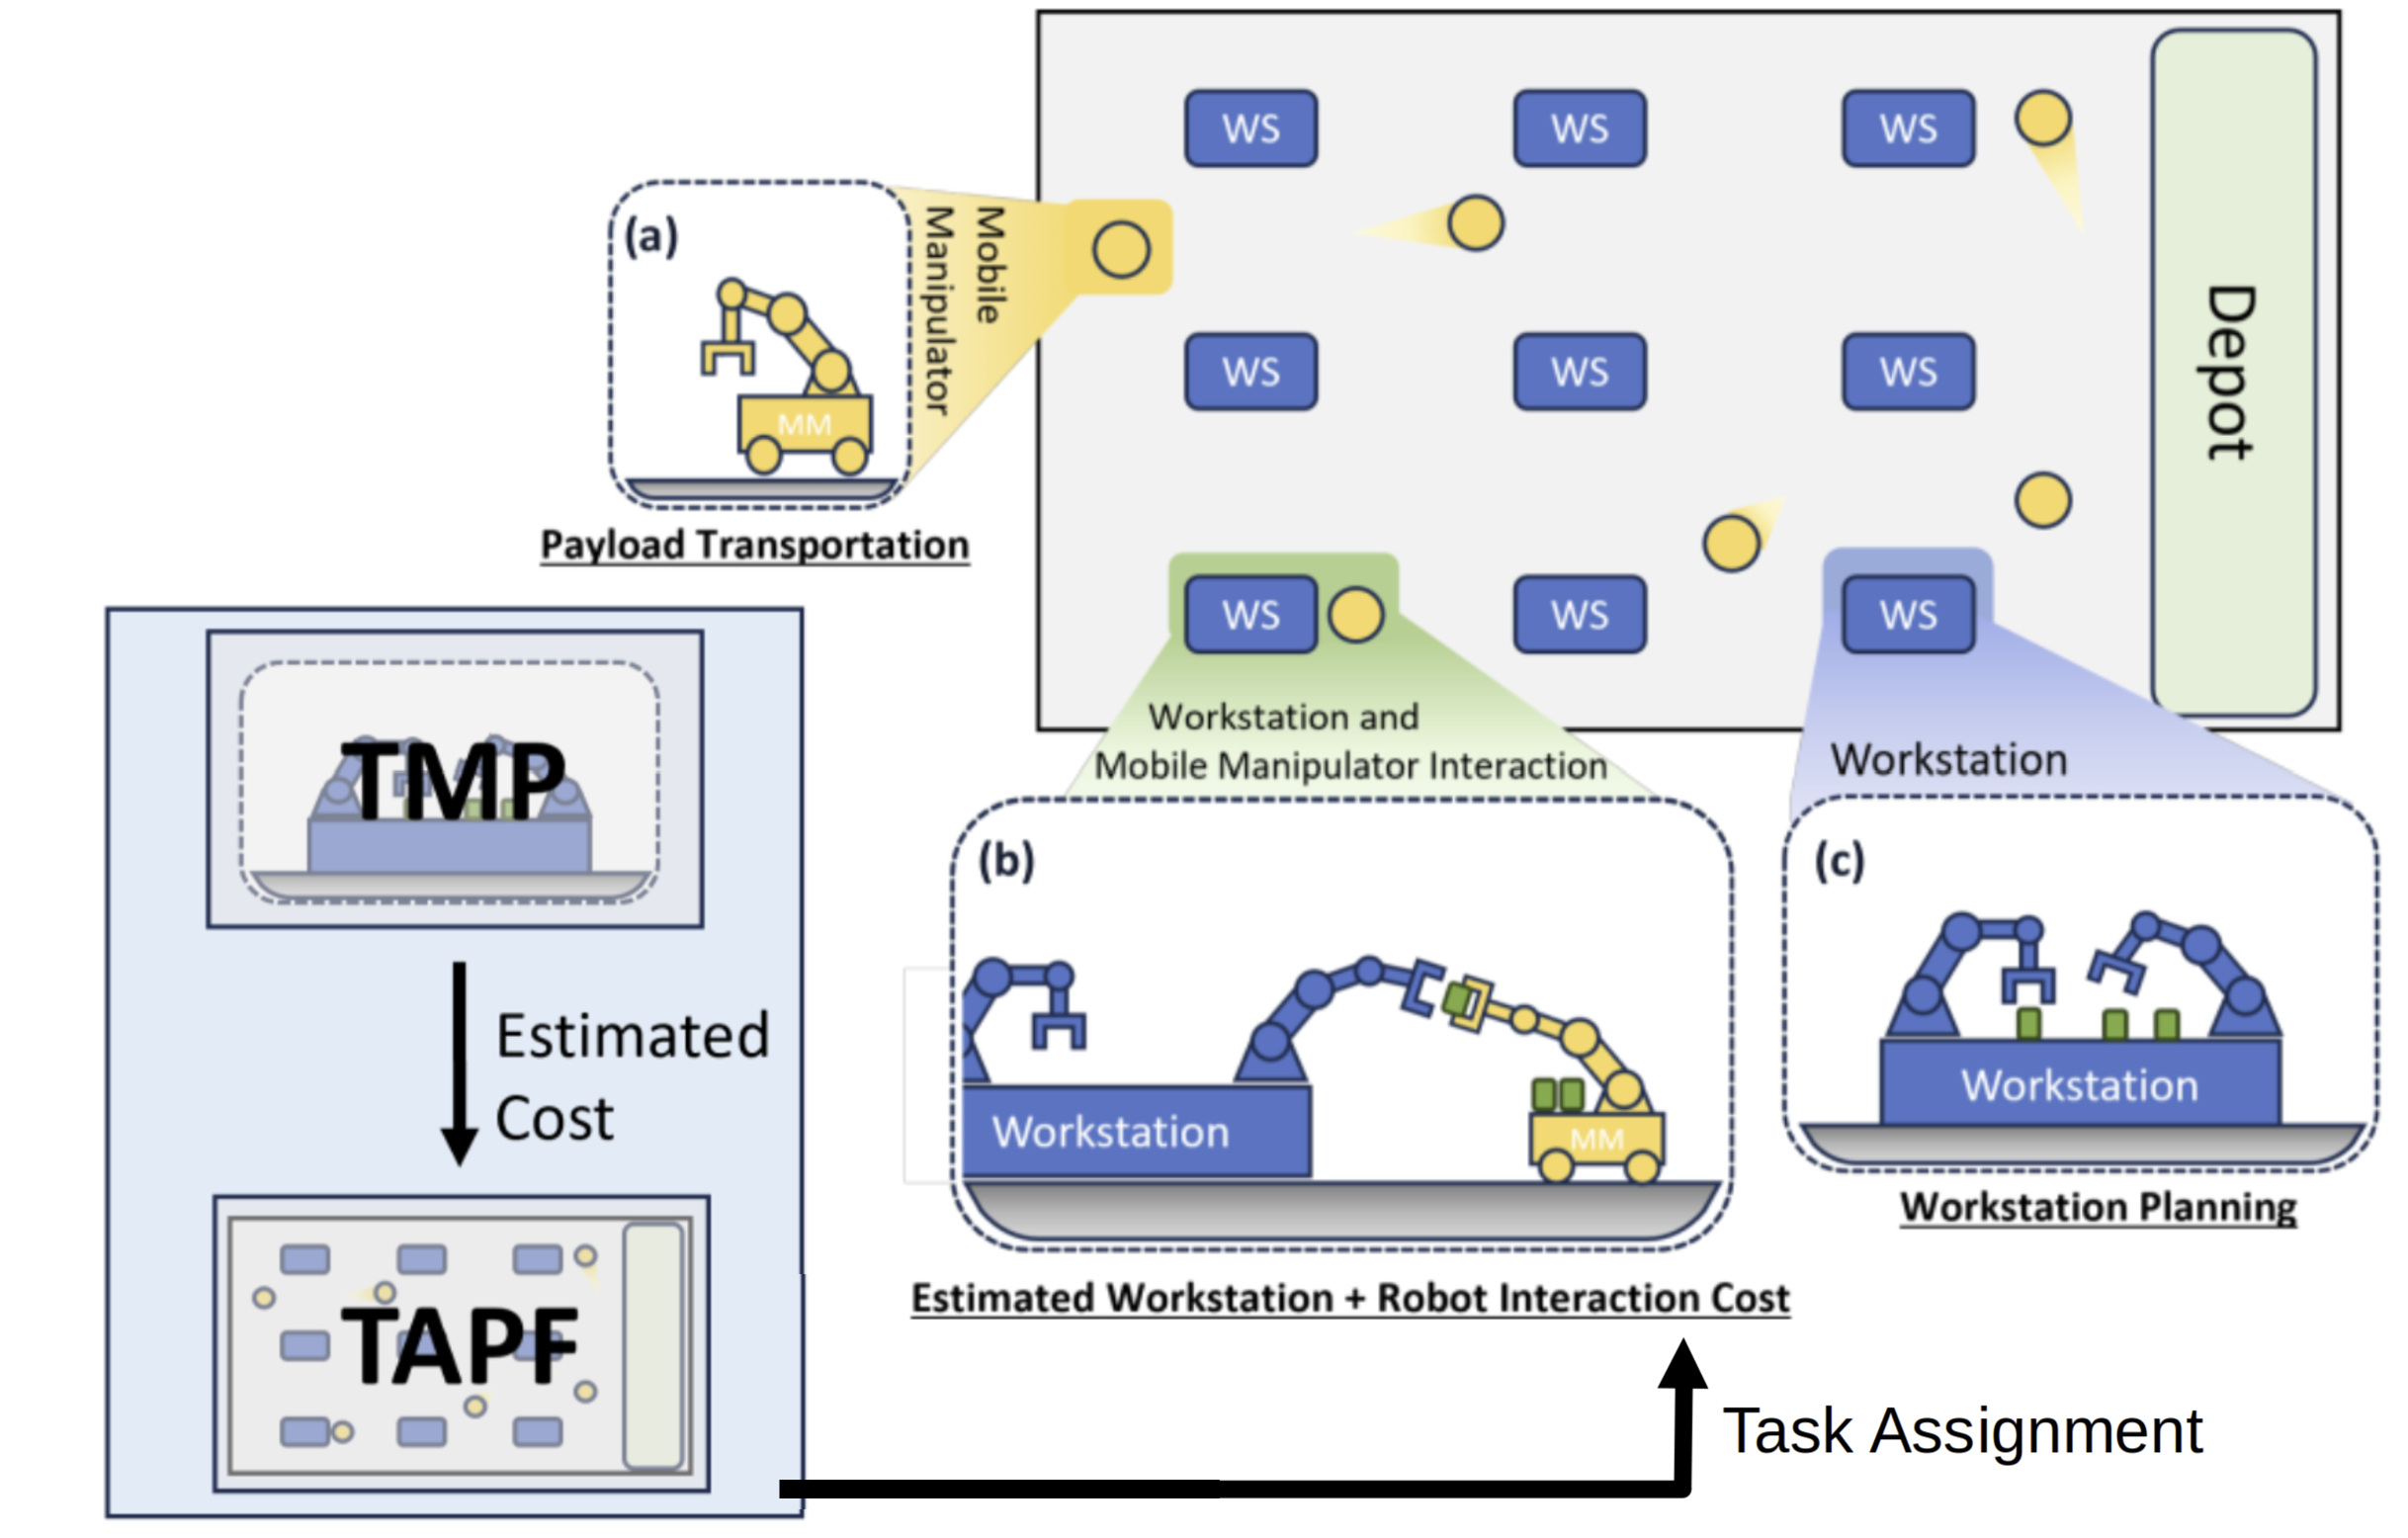
Reconfigurable Factory Image
A Hierarchical Approach to Workstation-based Task Allocation and Motion Planning
Driving Image
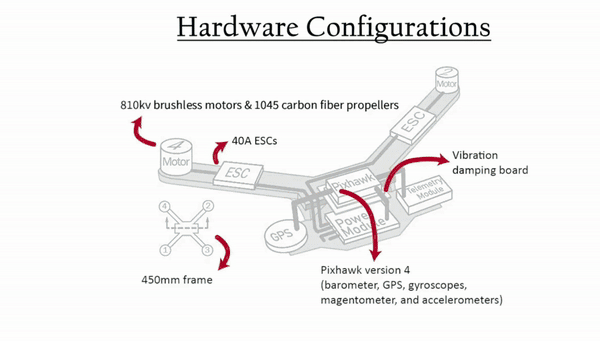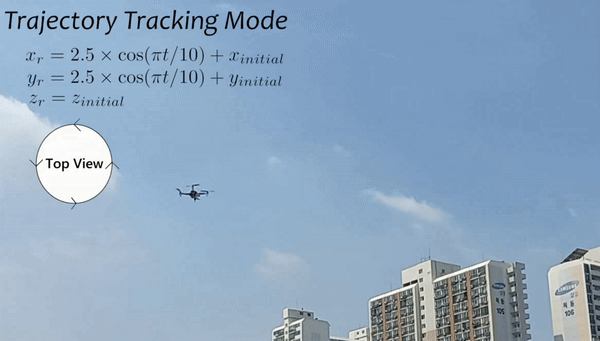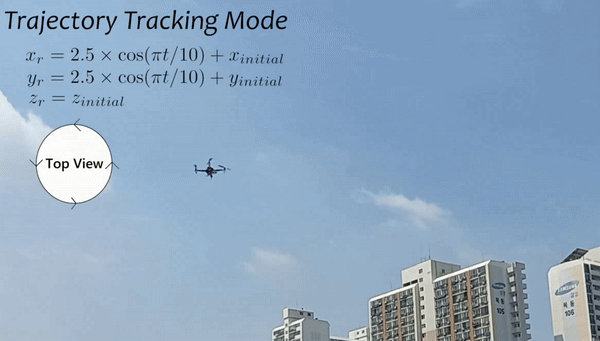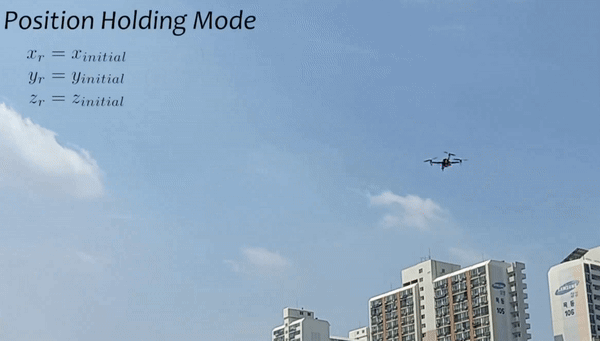
Output Feedback Control Design for Quadrotors Using Recursive Least Square Dynamic Inversion
Driving Image
Nonaffine Helicopter Control Design and Implementation Based on a Robust Explicit Nonlinear Model Predictive Control
Quadrotor Image
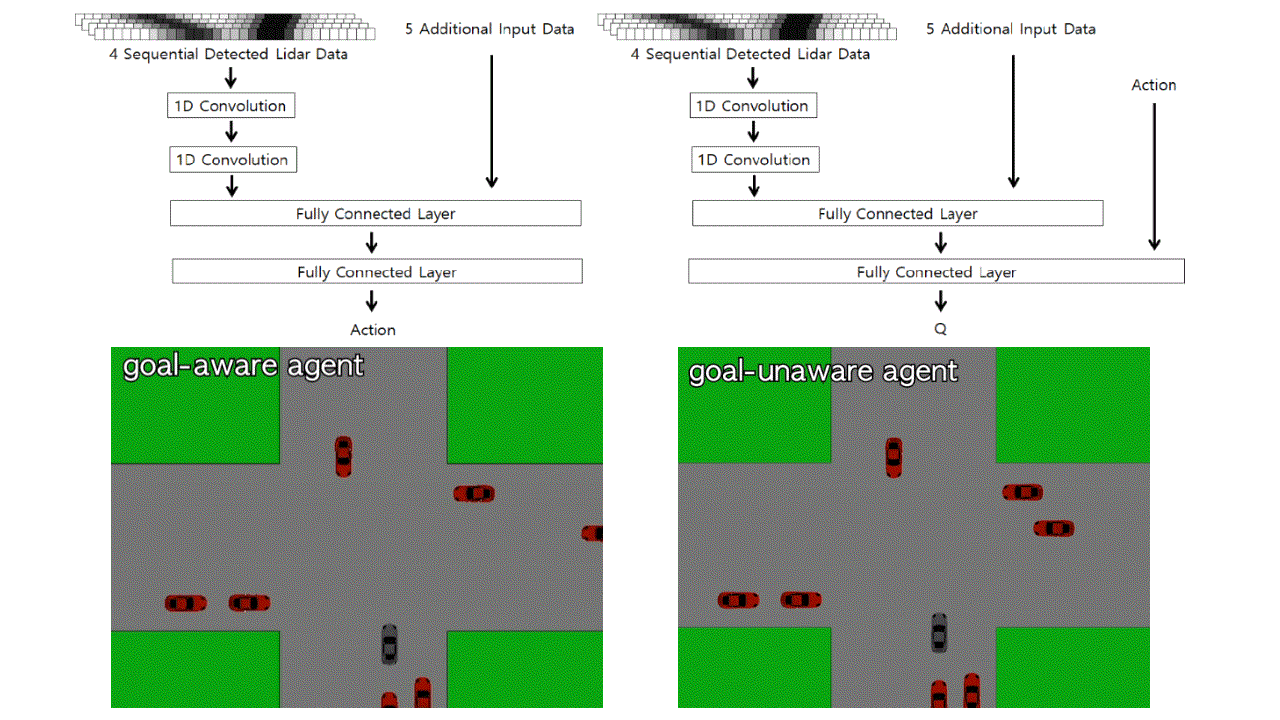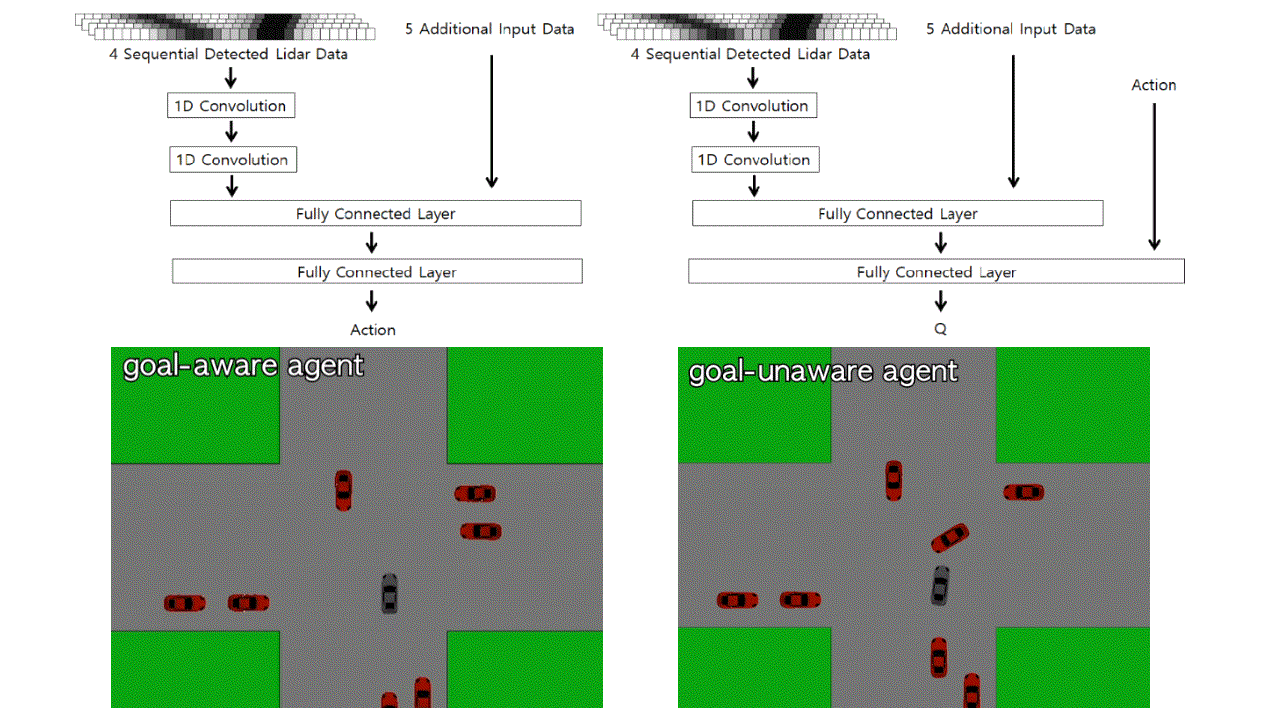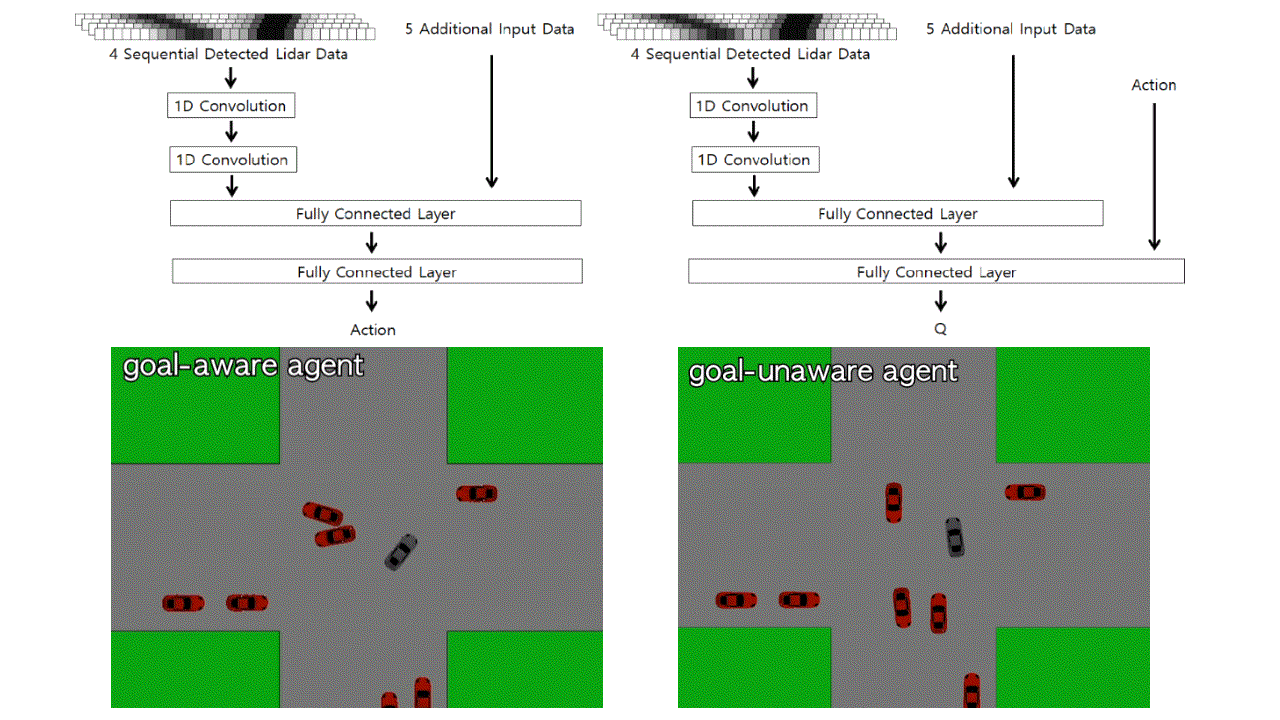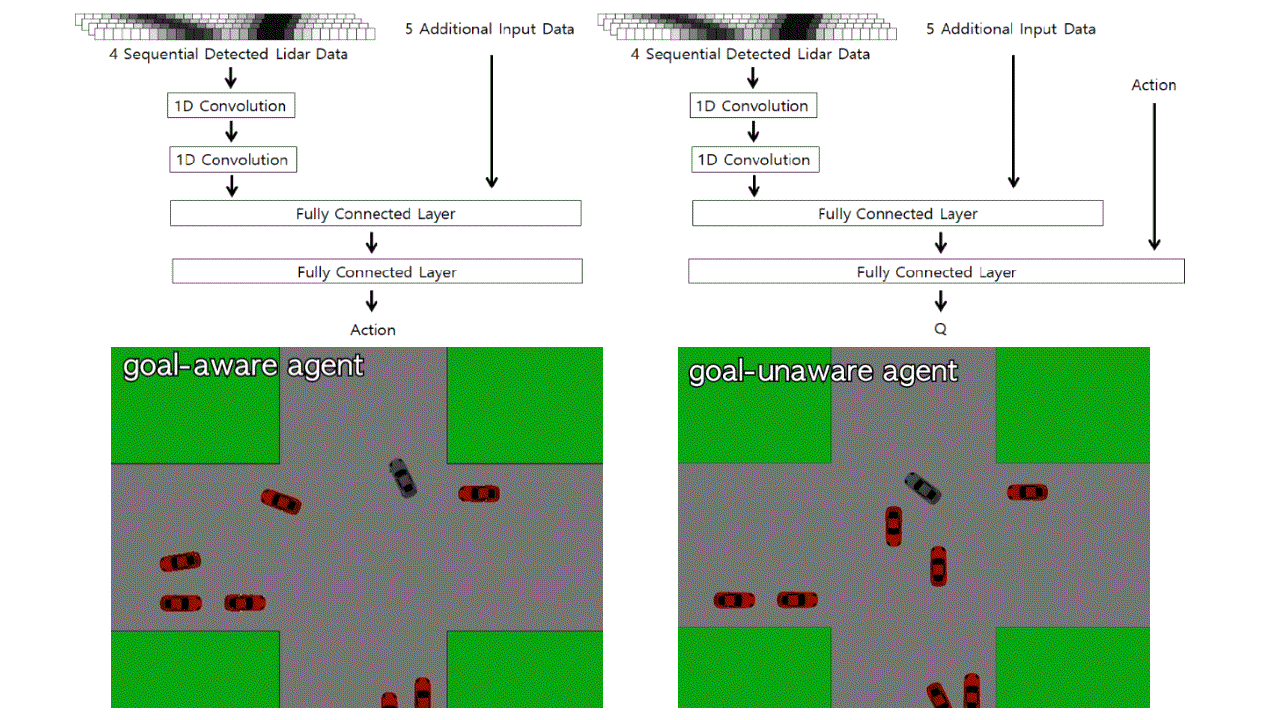
Unexpected Collision Avoidance Driving Strategy Using Deep Reinforcement Learning

Projects

Reconfigurable LEGO Factory workcell demo
Interactive demo
Reconfigurable LEGO Factory: Interactive Web Demo

An interactive 3D factory where multi-arm workcells assemble LEGO models while mobile manipulators fetch bricks, planned by a hierarchy of order assignment (MILP), multi-robot task planning and multi-arm motion planning. Configure a workcell's robot arms yourself, or watch the factory run with a live Gantt chart.
Quadrotor Image
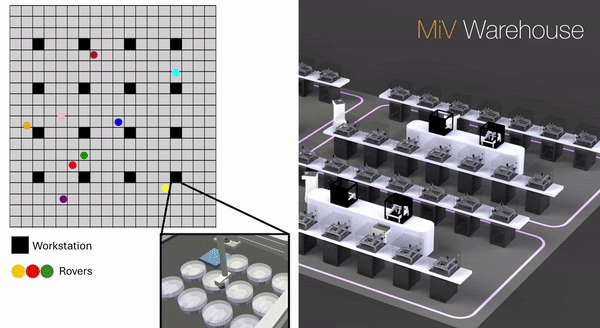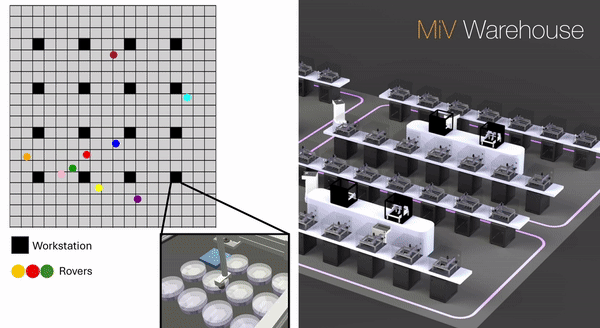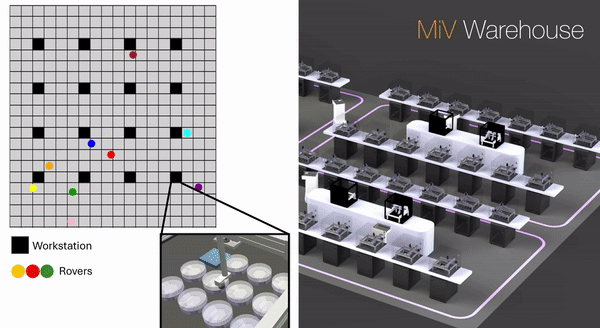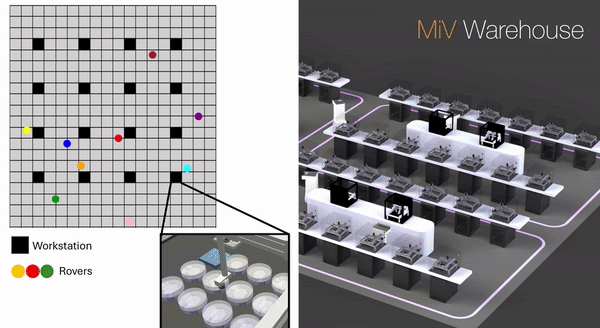
Mind in Vitro (MiV)

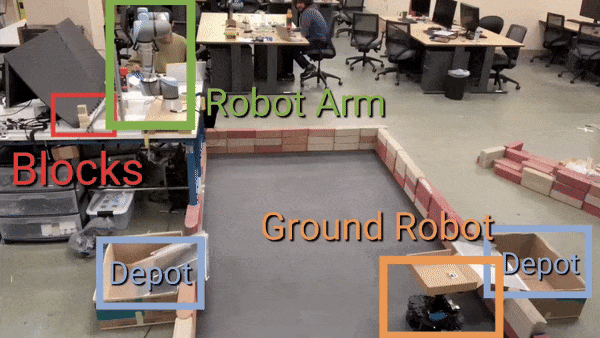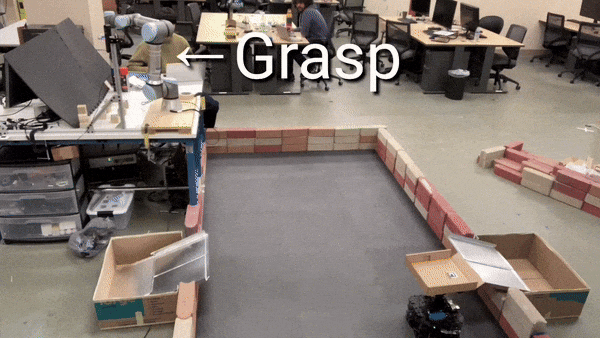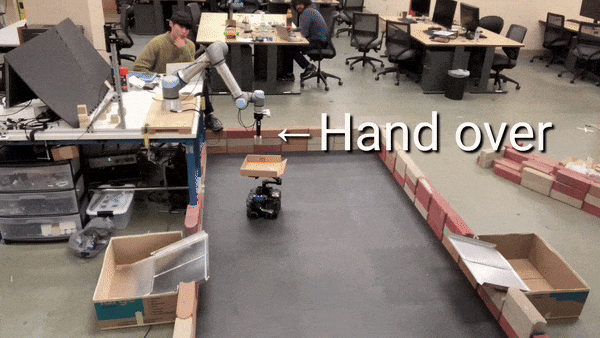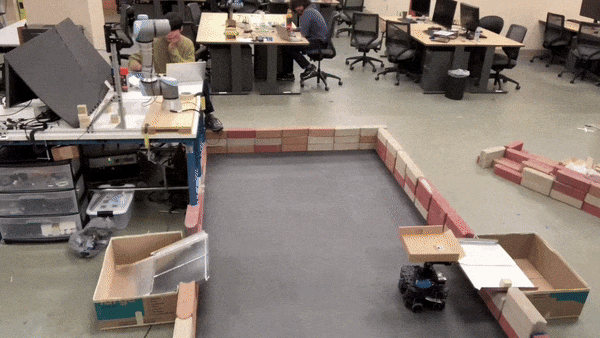
Developing an robotics automation system for a biology lab, funded by National Science Foundation (NSF)
Skills ROS Icon Python Icon Python Icon
Quadrotor Image
Factory Automation Demo

Demonstrated a simple factory automation demo to pre-college students at the Engineering Open House (EOH) at UIUC
Skills ROS Icon Python Icon Python Icon Python Icon
Quadrotor Image
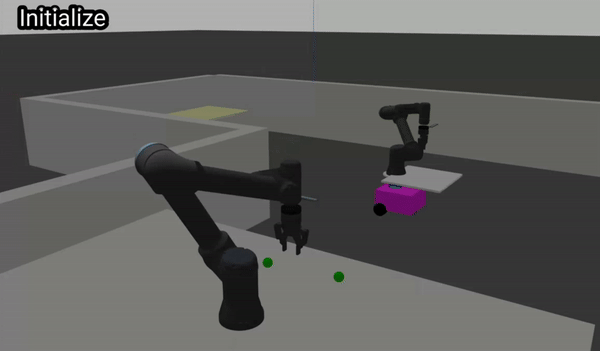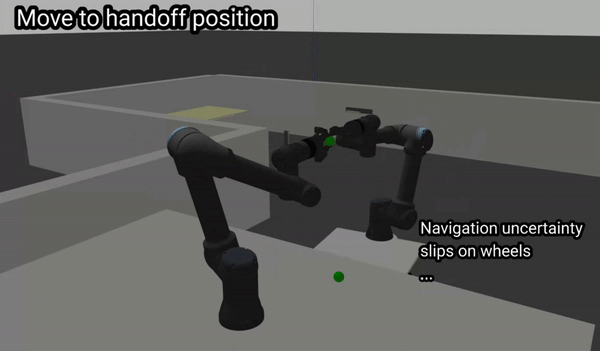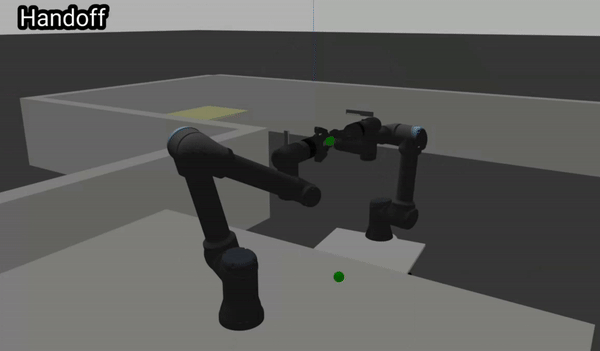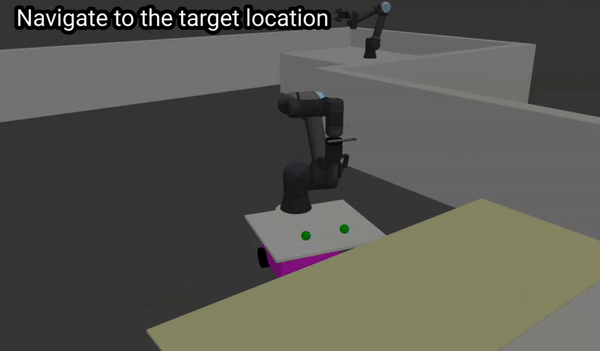
Robotics Course Project: Handoff Operation for Mobile Manipulators

Designed a vision-based system for handoff operations between a workstation and a mobile manipulator
Skills ROS Icon Python Icon Python Icon
Quadrotor Image
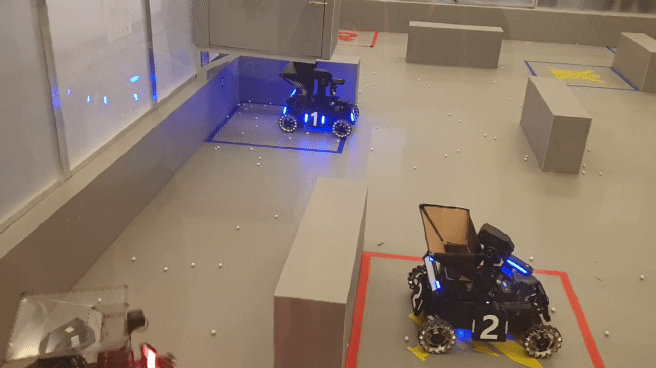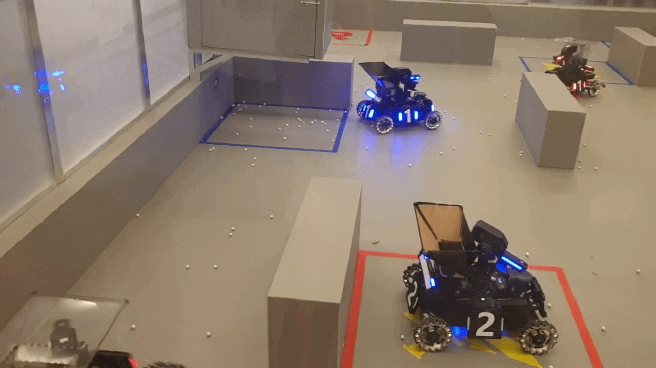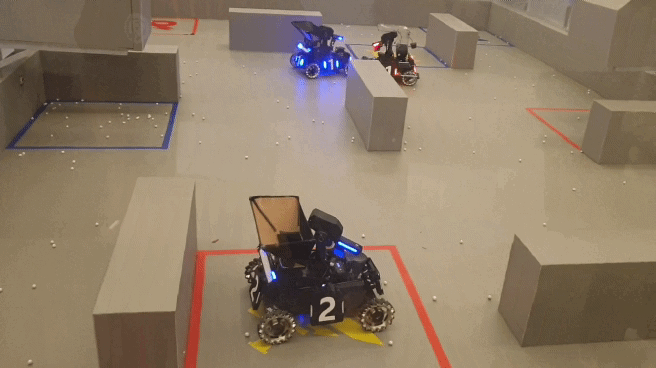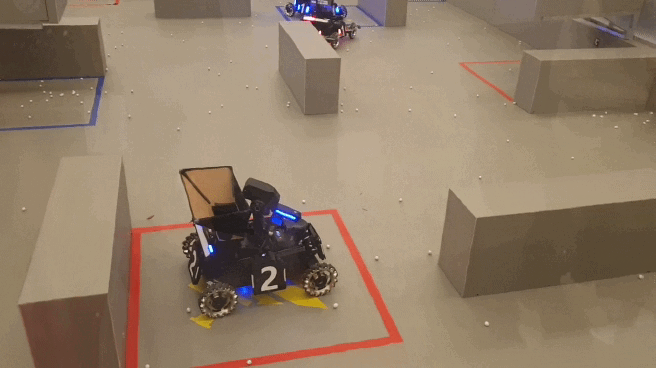
Robomaster AI Challenge ICRA2019

Implemented cooperative planning algorithms for fully autonomous combat robots (Achieved 3rd place)

Skills ROS Icon Python Icon Python Icon Python Icon

Professional Service

  • Reviewer
    • RAL, ICRA, IROS, WAFR (2022 - 2024)
  • Teaching & Mentoring
    • Research Program Mentor (CS), UIUC โ€“ Fall 2023, Summer 2024, Spring 2024
    • Fluid Mechanics (ME 310), UIUC โ€“ Fall 2022, Spring 2024, Fall 2024
    • Mathematical Methods (TAM 541), UIUC โ€“ Fall 2021